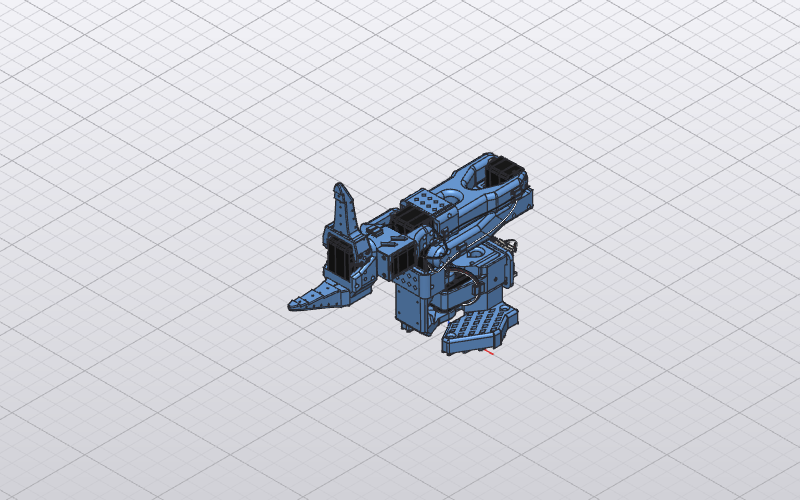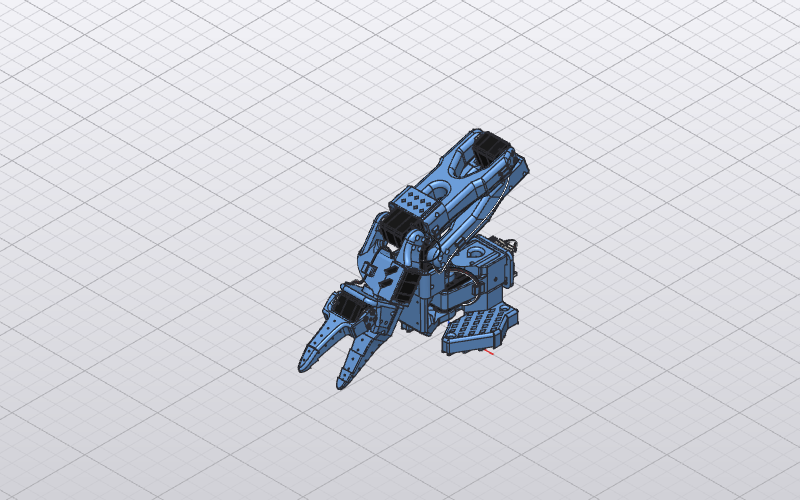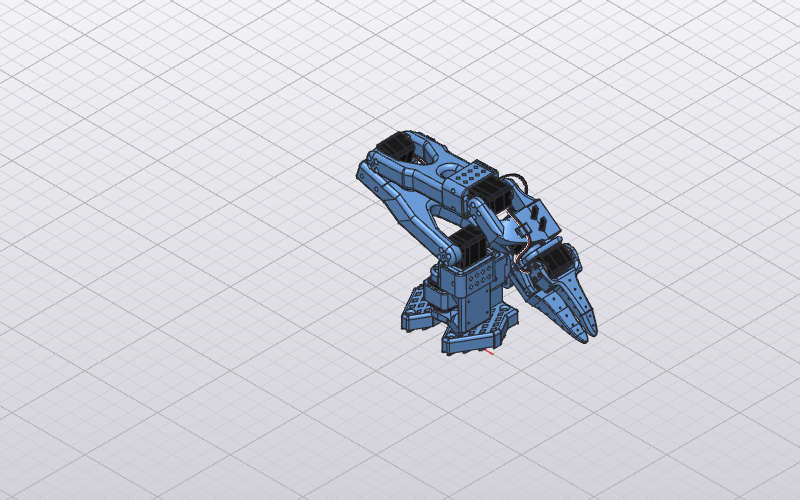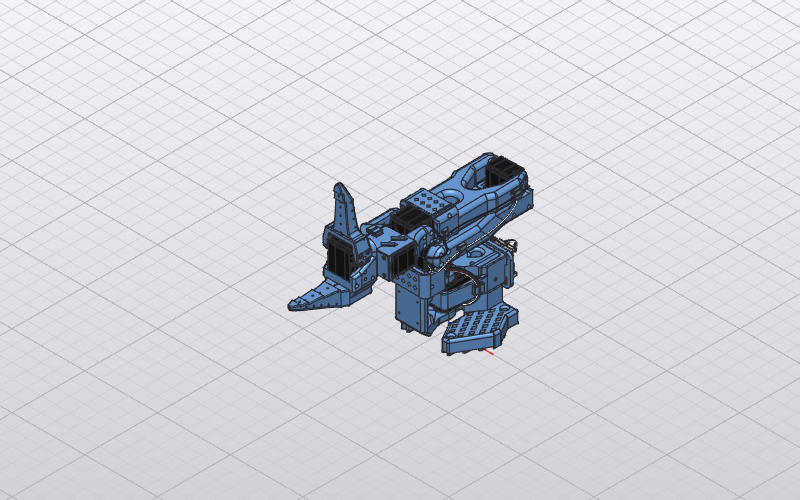
Import the STEP, turn its 97 parts into the arm's seven links, and give everything a real material. We said which printed parts belong to which link; the agent had to place every servo, screw, nut and "clip" by geometry.
- verifiedEvery one of the 267 bodies got a real material (PLA, steel, aluminium, FR-4, nylon, brass); the design totals 1,091 g
- verifiedEach servo landed in the link that holds its case, and each screw group in the link its horn drives
- notedThe "clips" turned out to be ribbon cables; it found that, and judged which side of a joint each one rides with
- notedThe servo CAD is solid envelopes that overlap inside, so real materials gave 48–90 g; it calibrated two densities to the datasheet's 55 g and said so
- notedExact contact checks took 20–30 minutes per call on this model, so it used distance measurements instead